
01 / ROBOTICS BUILD
Building a six-axis robot arm
Printing, assembling and testing a WE-R2.4 robot arm, starting with its motor-driven planetary joint.
Engineering portfolio
Robotics Engineering student at Tampere University with hands-on experience in robot programming, mechanical design and automation. Currently looking for an internship or student role in robotics, intelligent machines or industrial automation.
Selected work
Printing, assembling and testing a WE-R2.4 robot arm, starting with its motor-driven planetary joint.
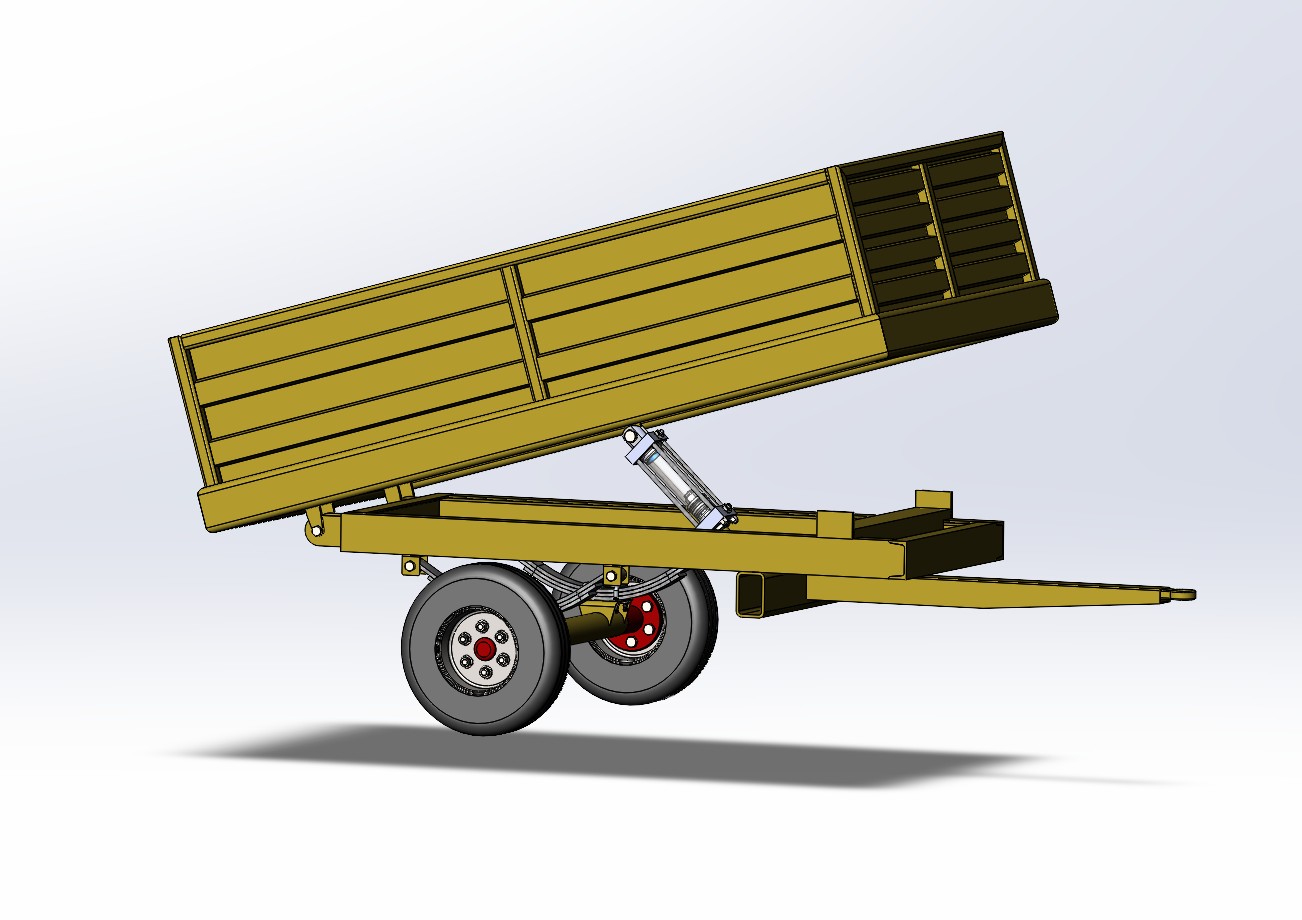
A SolidWorks assembly exploring hydraulic cylinder movement, geometry and mechanical constraints.
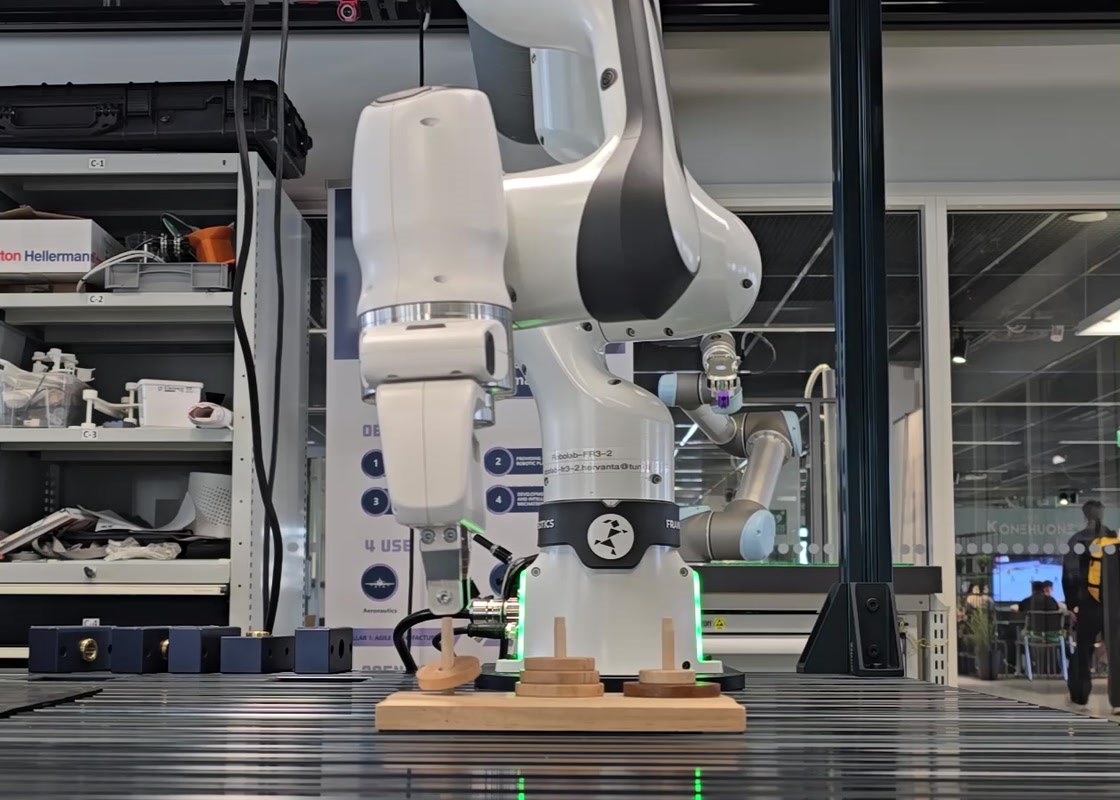
A physical robot programmed to solve the puzzle using a planned move sequence and taught positions.
What I’m looking for
I’m currently looking for an internship, student role or project collaboration where I can grow as an engineer and contribute as part of a team.